Track drone position and attitude with low latency in indoor flight spaces to support control algorithm development and swarm flight experiments.
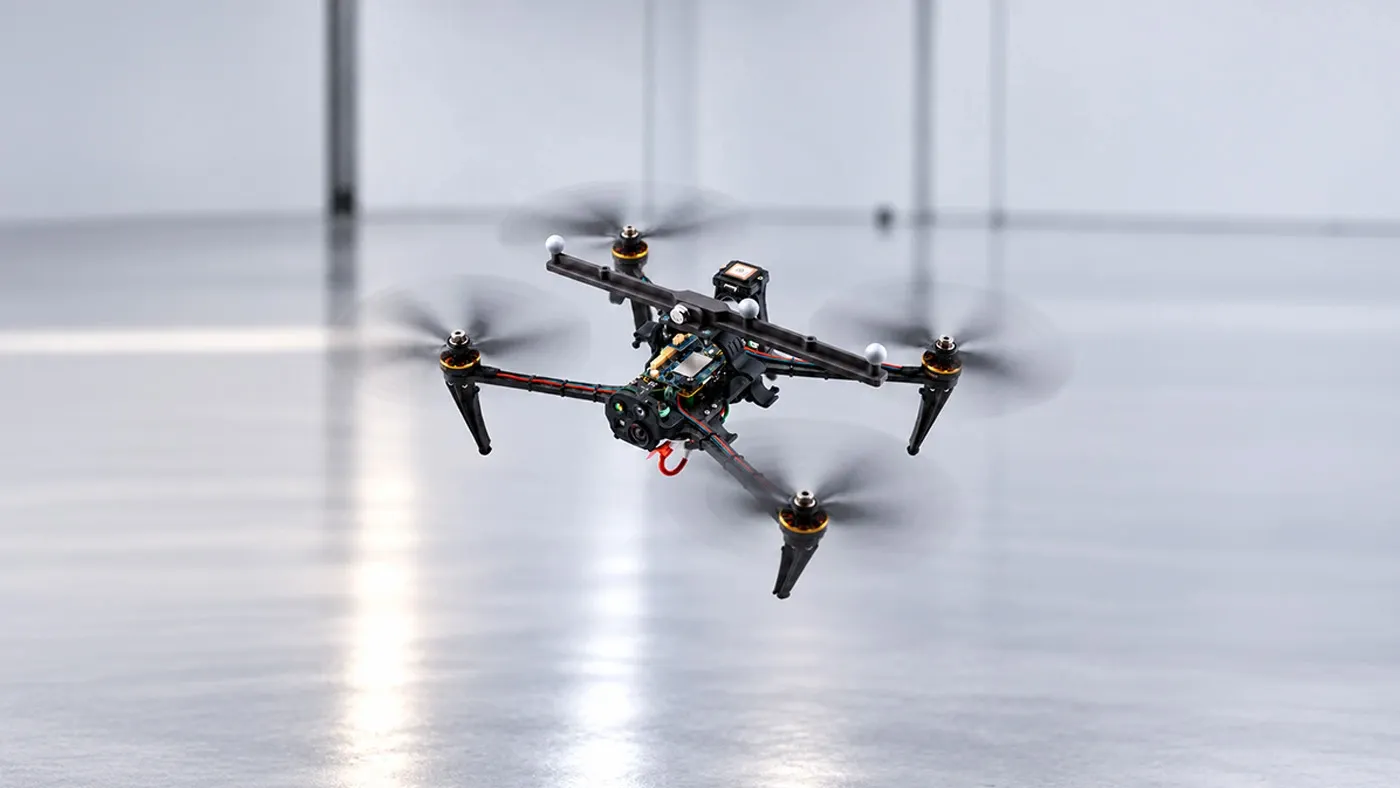
Flying drones stably indoors, where GPS doesn't reach, requires a system that tells them their position from outside. Optical tracking delivers the 6-DoF pose of fast-moving drones to flight controllers such as PX4 and ArduPilot with only a few milliseconds of latency, enabling precise position control and trajectory-following experiments.
Applying a different marker layout to each drone lets you track swarm flights simultaneously, and filter settings tuned for high-speed flight plus long-range cameras covering large volumes make large flight arenas possible.
Typical uses
- Indoor drone position control (PX4 · ArduPilot integration)
- Swarm flight and cooperative control experiments
- Recording high-speed maneuver trajectories and analyzing control performance
- Building large indoor flight arenas