Quantitatively evaluate the error of camera- and LiDAR-based localization algorithms against a drift-free reference trajectory.
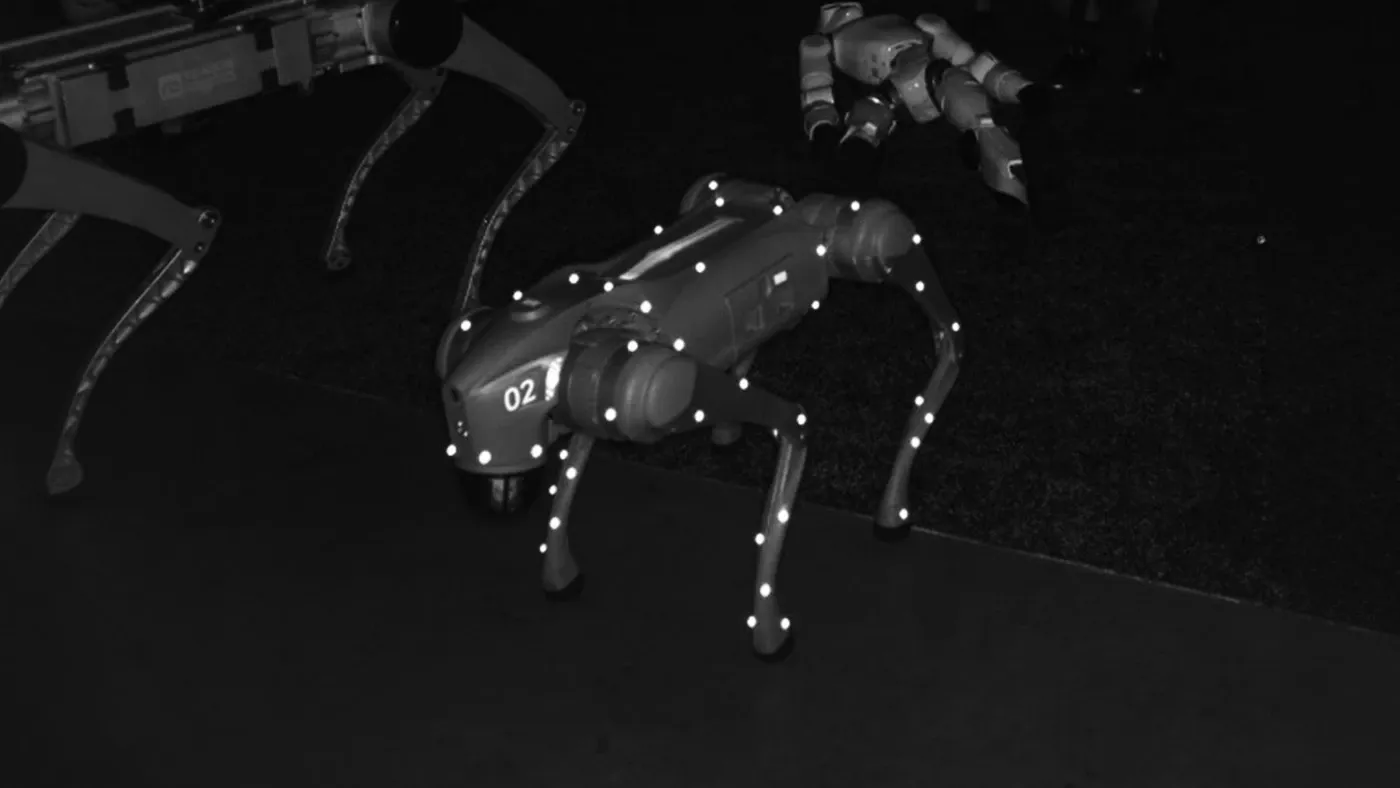
To evaluate the localization performance of Visual SLAM, LiDAR odometry and autonomous mobile robots (AMRs), you need to know the "true position". Optical motion capture records the 6-DoF (position + rotation) trajectory of markers on the robot with error under 0.3 mm, providing reference data you can compare directly with algorithm output.
ROS 2 integration (MoCap4ROS2) and the NatNet SDK stream the reference trajectory straight into robot software, and continuous calibration during operation keeps the reference steady over long experiments. Configurations range from lab scale to large warehouse-sized spaces.
Typical uses
- Accuracy evaluation of Visual SLAM and LiDAR odometry
- Localization validation for autonomous mobile robots (AMRs)
- Real-time reference trajectory to ROS 2
- Multi-robot cooperative navigation experiments