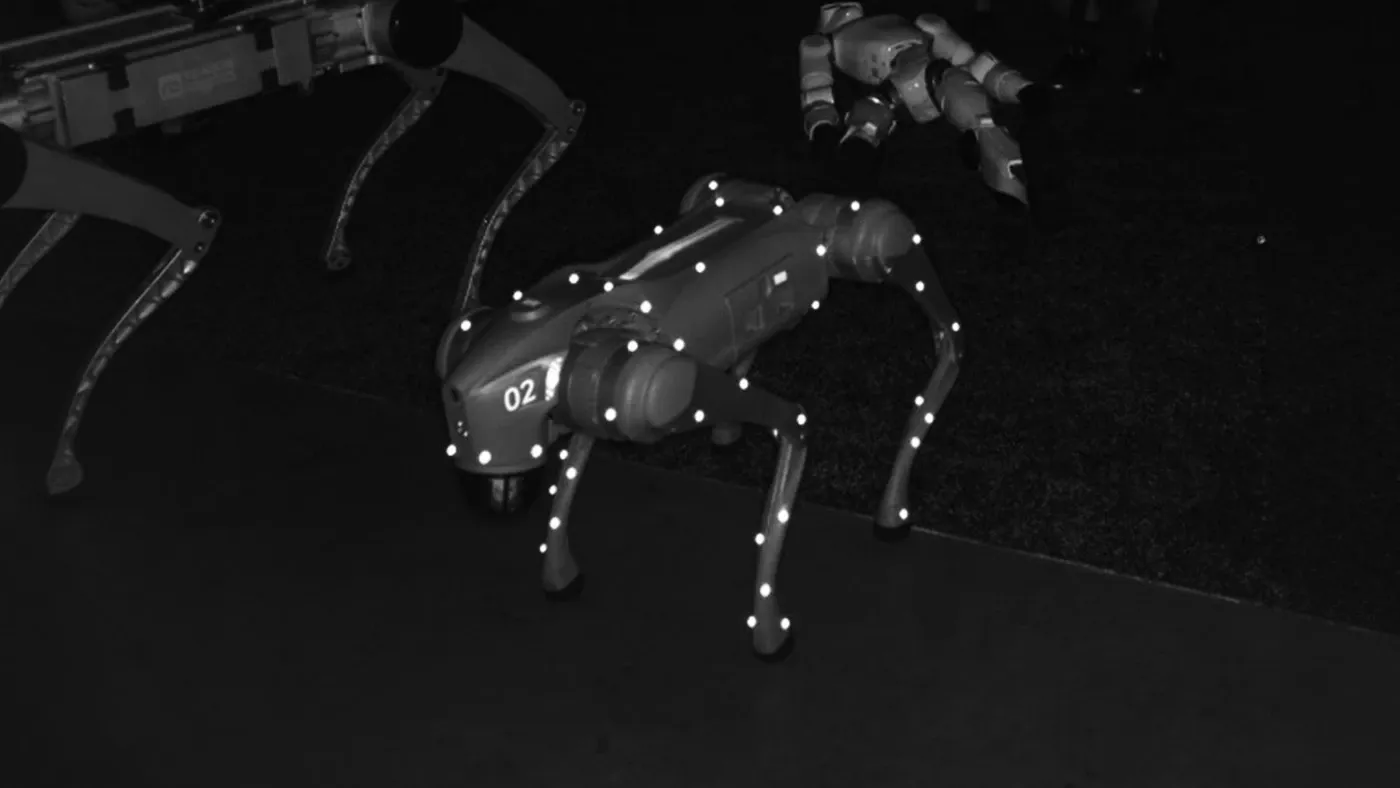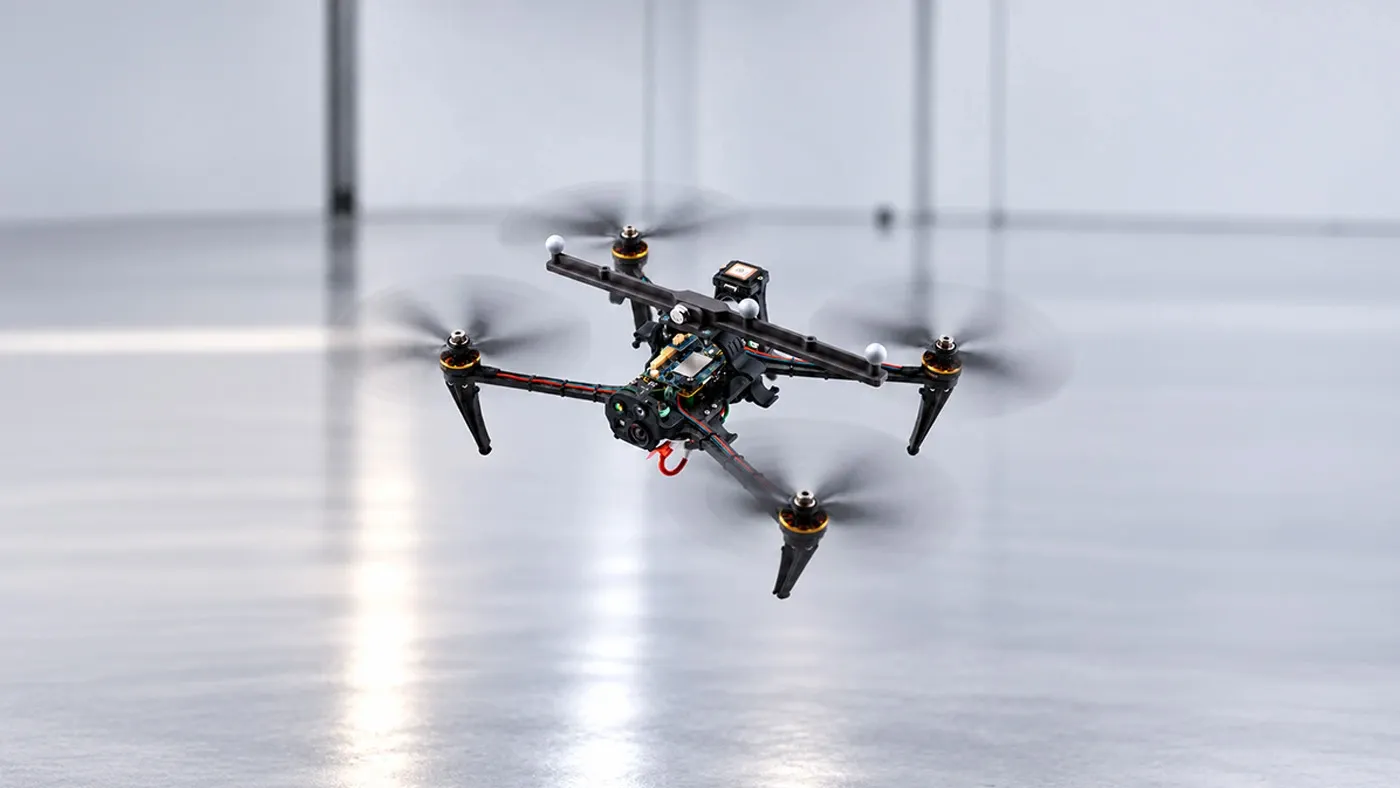
Record full-body human movement precisely to use as imitation-learning data for humanoid robots, or to control robots in real time.
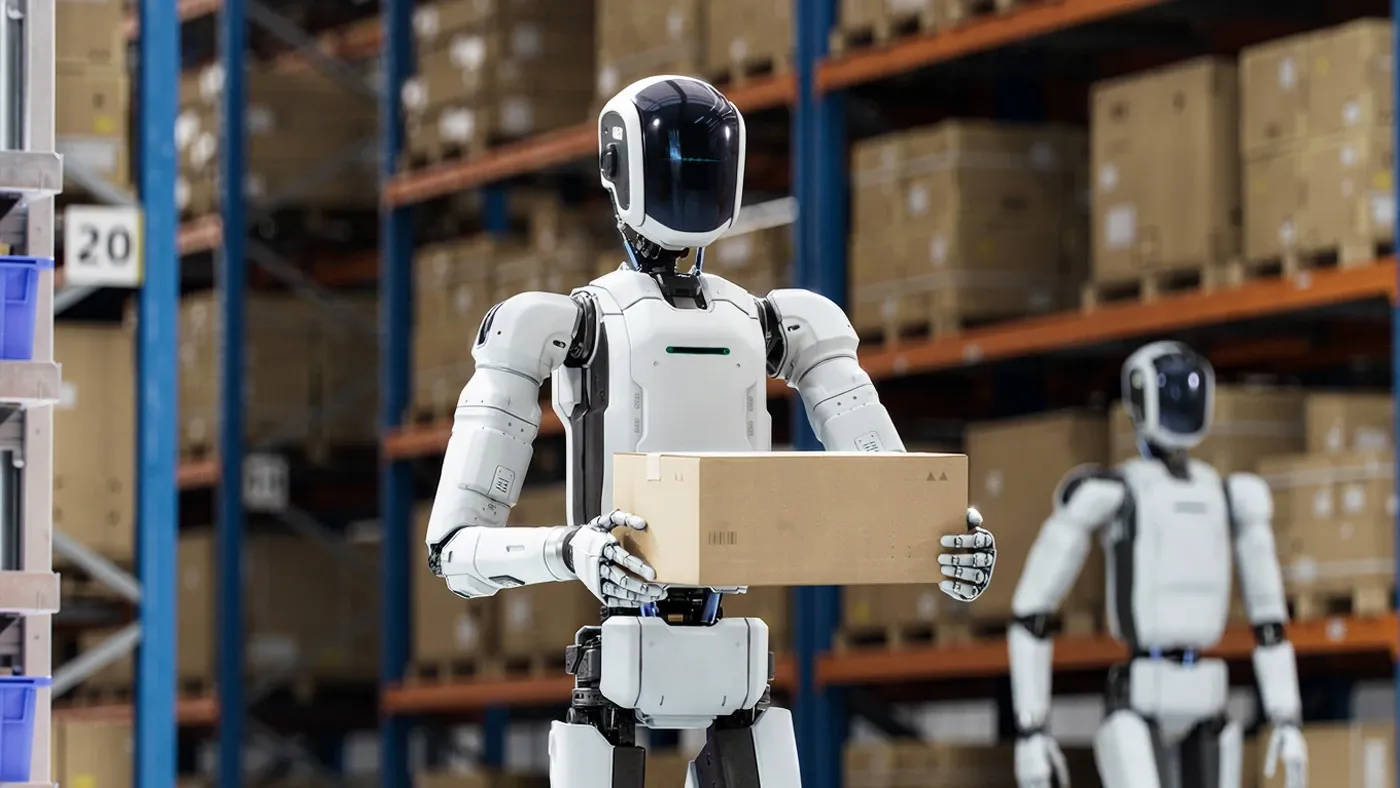
For humanoid robots to walk and handle objects like people, they need large amounts of human motion data. Optical motion capture records joint trajectories with high precision, and finger-tracking gloves capture fine hand manipulation, building the base data for imitation learning and retargeting.
You can also set up teleoperation that transfers the movements of an operator wearing an inertial suit and gloves to the robot in real time. Recording the robot's actual movement with the optical system at the same time lets you analyze the difference between command and result quantitatively.
Typical uses
- Building full-body and hand motion datasets for imitation learning
- Validating human-to-robot motion retargeting
- Real-time teleoperation with wearable sensors
- Precise recording and evaluation of actual robot motion