ATI

6-Axis Force/Torque Sensor
A sensor that measures the force and torque on a robot along six axes (Fx·Fy·Fz·Tx·Ty·Tz) simultaneously. Used for force control, precision assembly and research measurement of interaction forces.
Features
Mounted on a robot wrist or fixture, it measures force in three directions and torque about three axes at once. Readings can be used for logging and monitoring or sent to the robot controller in real time for force control. ATI is a specialist manufacturer that has produced force/torque sensors for more than 30 years.
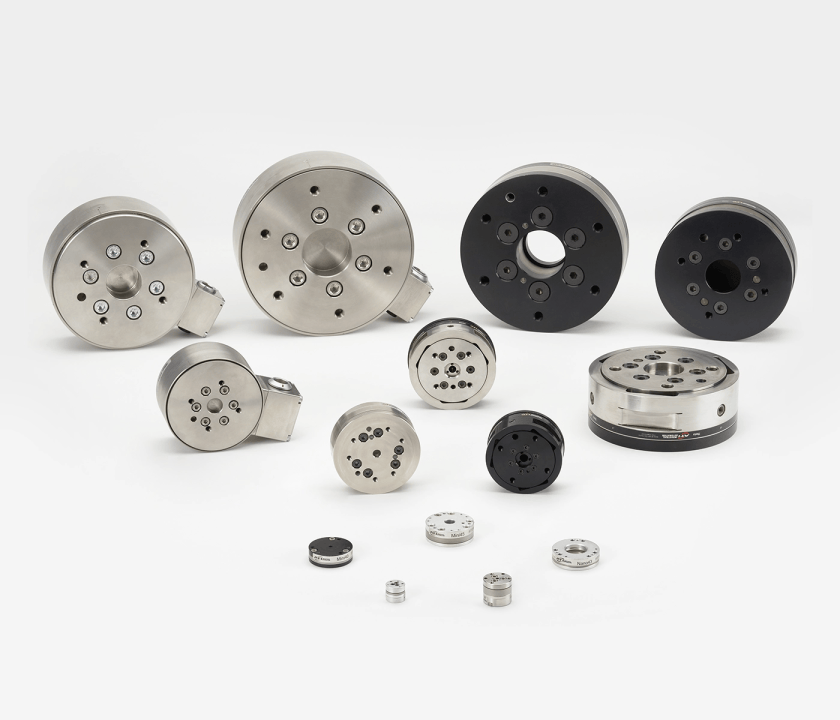
- A wide lineup from the ultra-compact 17 mm Nano17 to the large 330 mm Omega331 — choose measuring ranges from tens of N to tens of kN
- Choose from integrated-electronics (Axia series) or external-electronics models and several performance grades to suit your application
- Interface, mounting surface and calibration range configured to order; waterproof/dustproof (IP65/IP68), vacuum and radiation-resistant versions available
- FANUC-Ready kits (Axia, GEN3) connect directly to FANUC robots and force control software, shortening integration time
- Calibration files provided — easy integration with research data acquisition equipment
Specifications
Main series
| Series | Representative models | Features |
|---|---|---|
| Axia | Axia80 · Axia90 · Axia130 | Built-in electronics; mounts directly on collaborative and industrial robots |
| Nano | Nano17 · Nano25 | Ultra-compact and ultra-light (from 9 g), for medical and precision research |
| Mini | Mini27 · Mini40 · Mini45 · Mini58 | General-purpose line for small robots and grippers |
| Gamma · Delta | Gamma · Delta | Industrial standard size, IP60/65/68 options |
| Omega | Omega160 · 191 · 250 · 331 | High load (up to Fz ±88 kN) for large robots and test equipment |
Rated ranges and dimensions for each model are in the comparison table on the manufacturer's product page, and different calibration ranges can be applied to the same sensor.
Images

Videos
More from ATI

Automatic Tool Changer
A device that automatically swaps the gripper or work tool at the end of a robot arm. One robot handles several processes, raising equipment utilization.
Utility Couplers
6-axis force/torque sensors and robotic tool changers.

Deburring Tool
A tool that lets robots remove burrs, sharp edges and parting lines left on machined parts. Built-in compliance delivers a uniform finish.

Collision Sensor
Instantly detects unexpected impacts on the robot tool, stops the robot and absorbs the shock to reduce damage to the tool, robot and workpiece.