ATI

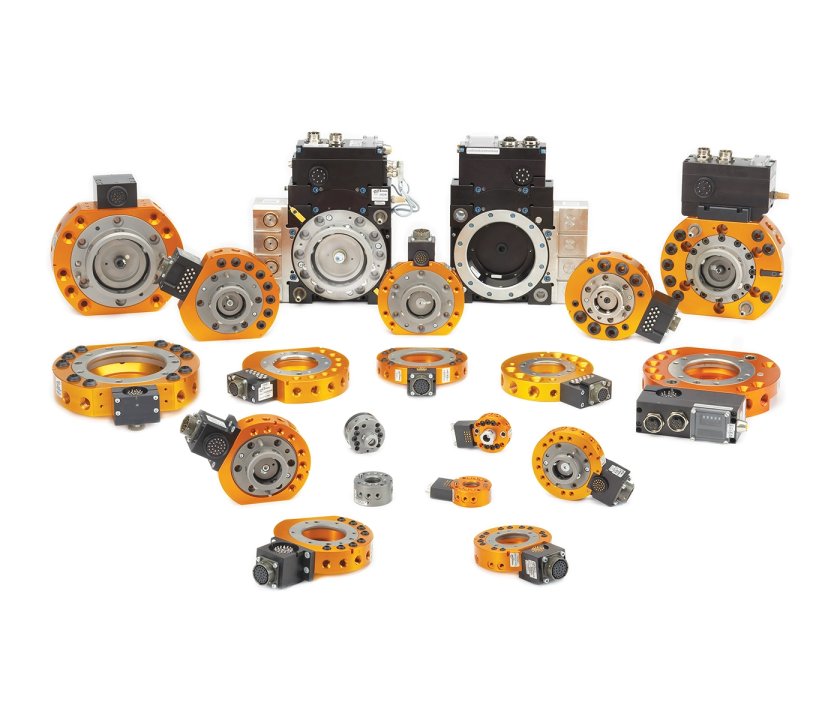
Automatic Tool Changer
A device that automatically swaps the gripper or work tool at the end of a robot arm. One robot handles several processes, raising equipment utilization.
Features
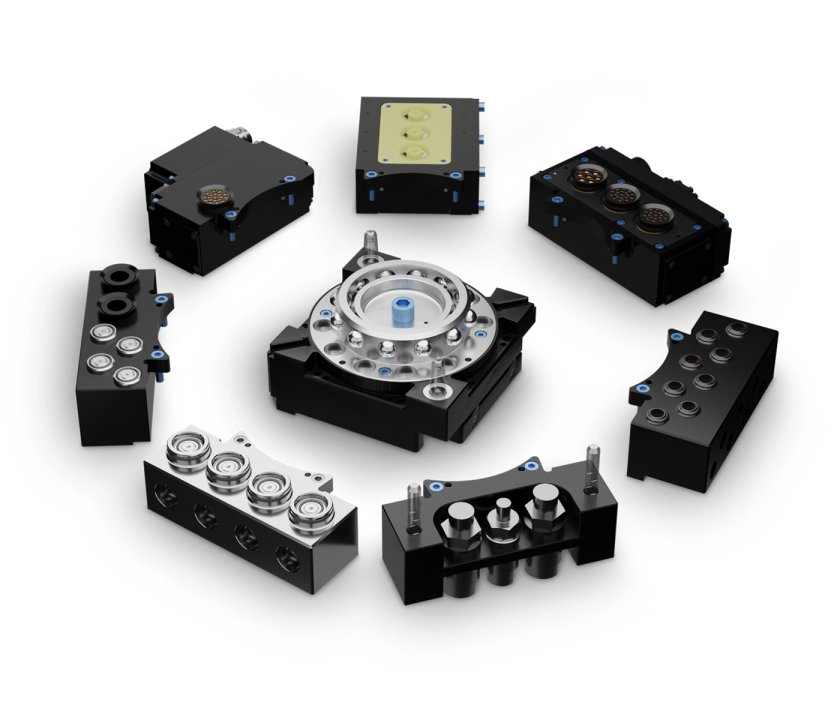
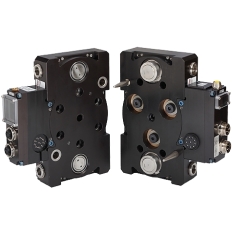
Split into a robot side (master) and a tool side (tool), the robot picks up and locks the gripper, welding gun or spindle it needs from a tool stand on its own. Electrical, pneumatic and fluid signals pass through modules straight to the tool.
- Payloads from 1.4 kg to 4,000 kg class — from small collaborative robots to large industrial robots
- Durability for millions of changes at rated load, with high repeatability
- Choose pneumatic (QC series) or manual (MC series) changers
- More than 100 pass-through modules for electrical signals, fluids, air, Ethernet and more
- Control/valve modules for locking, unlocking and communication, and modular tool stands for tool storage
Specifications
Representative models (pneumatic QC series)
| Payload range | Representative models |
|---|---|
| ~16kg | QC-1 · QC-7 · QC-11 |
| 18~50kg | QC-18 · QC-20/21/22/29 · QC-40Q · QC-46 · QC-50 |
| 100~300kg | QC-76 · QC-110 · QC-113 · QC-160 · QC-210 · QC-213 |
| 300~700kg | QC-310 · QC-313 · QC-510 · QC-850 |
| 1,350~4,080kg | QC-1210 · QC-1310 · QC-1510 |
Manual changers: MC-16R (16 kg) · MC-36R (36 kg) · MC-50 (30 kg). See the manufacturer's product page for detailed specifications.
Images
Videos
More from ATI

6-Axis Force/Torque Sensor
A sensor that measures the force and torque on a robot along six axes (Fx·Fy·Fz·Tx·Ty·Tz) simultaneously. Used for force control, precision assembly and research measurement of interaction forces.
Utility Couplers
6-axis force/torque sensors and robotic tool changers.

Deburring Tool
A tool that lets robots remove burrs, sharp edges and parting lines left on machined parts. Built-in compliance delivers a uniform finish.

Collision Sensor
Instantly detects unexpected impacts on the robot tool, stops the robot and absorbs the shock to reduce damage to the tool, robot and workpiece.