ATI

Collision Sensor
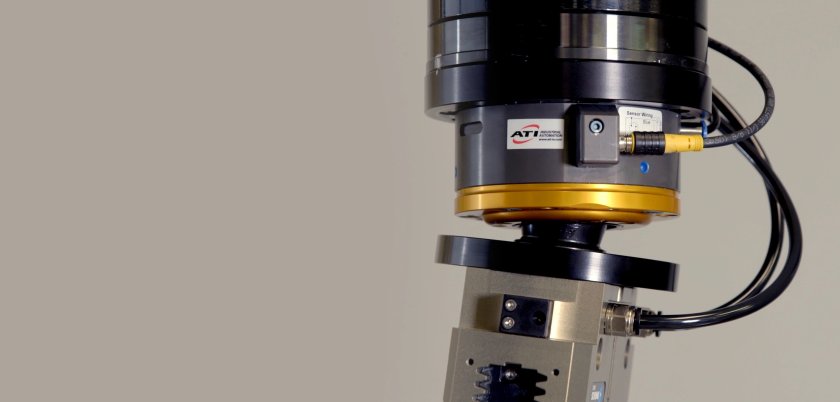
Instantly detects unexpected impacts on the robot tool, stops the robot and absorbs the shock to reduce damage to the tool, robot and workpiece.
Features
A safety device mounted between the robot wrist and the tool. When a collision exceeds the set force or moment, the sensor breaks away and sends a signal to stop the robot, then returns to its original position once the collision is cleared.
- Protects equipment and workers and prevents accidents
- Reduces downtime and repair costs from collisions
- Sensitivity (break-away force) adjusted pneumatically — set sensitivity to suit the task
- Easy to mount on a wide range of robots; 8 models by size and load (SR-48 to SR-221)
Specifications
Specifications by model
| Model | Angular displacement | Axial displacement | Weight | Moment break-away | Axial break-away |
|---|---|---|---|---|---|
| SR-48 | ±13° | 5.1mm | 0.25kg | 2.3~6 Nm | 440 N |
| SR-61 | ±11° | 5.6mm | 0.32kg | 6.8~28 Nm | 880 N |
| SR-81 / SR-82 | ±13° | 8.6mm | 0.58kg | 14~59 Nm | 1,700 N |
| SR-101 | ±12° | 10mm | 1.18kg | 27~120 Nm | 2,700 N |
| SR-131 | ±10° | 12mm | 2.31kg | 76~340 Nm | 4,700 N |
| SR-176 | ±10° | 16mm | 5.44kg | 180~810 Nm | 8,900 N |
| SR-221 | ±8° | 16mm | 11.4kg | 440~2,000 Nm | 14,000 N |
Axial break-away is at 6.2 bar; moment break-away is over a 1.4–6.2 bar pneumatic range.
Images
Videos
More from ATI

6-Axis Force/Torque Sensor
A sensor that measures the force and torque on a robot along six axes (Fx·Fy·Fz·Tx·Ty·Tz) simultaneously. Used for force control, precision assembly and research measurement of interaction forces.

Automatic Tool Changer
A device that automatically swaps the gripper or work tool at the end of a robot arm. One robot handles several processes, raising equipment utilization.
Utility Couplers
6-axis force/torque sensors and robotic tool changers.

Deburring Tool
A tool that lets robots remove burrs, sharp edges and parting lines left on machined parts. Built-in compliance delivers a uniform finish.